I am a staff researcher at Stanford University, where I work on training world models to enable autonomous decision-making in robotic systems. I like building systems that can interact with the physical world and solve meaningful problems for people. Above all, I love working on hard problems with good people.
Previously, I was a founding engineer at Capella Space, where I led the spacecraft operations group that successfully developed a fully-automated constellation operations system. I subsequently led the constellation operations and space safety group at Project Leo (Kuiper) and have worked on a variety of other projects across robotics, space systems, cybersecurity, and distributed systems. I got my PhD in Aerospace Engineering at Stanford University in the Stanford Intelligent Systems Laboratory (SISL).
Astrodynamics Software
One of my longest-running projects is the development of open-source astrodynamics software. I try to make it high-quality, accessible, and understandable to enable others to build on it to solve their own challenges without having to reinvent the astrodynamics "wheel". This work started when I was beginning my graduate studies and found that there weren't easily accessible, easy-to-use astrodynamics software packages that I could both quickly integrate into my work and easily dig into the implementation details to understand how algorithms were implemented.


Selected Recent Work
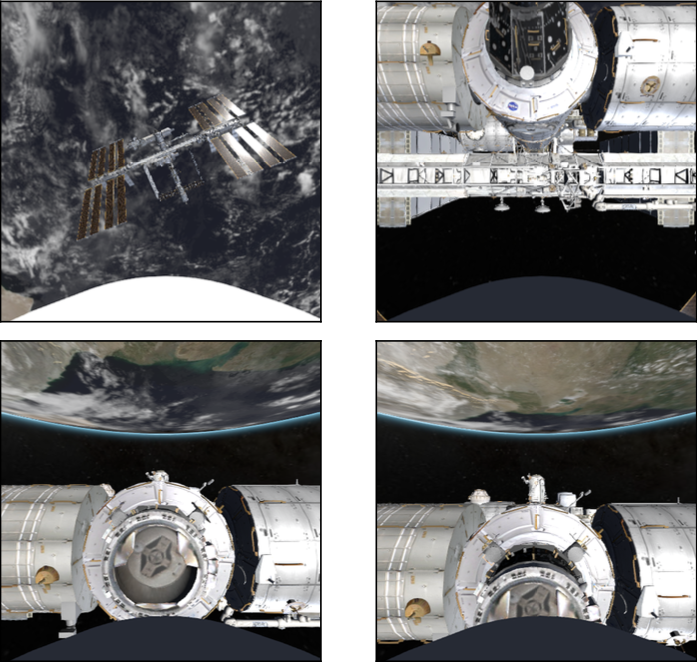
Out of this World Model
Learned system models can efficiently fuse and predict the future state of complex, high-dimensional systems. We train a world model and use it to successfully dock with the International Space Station using just 7 hours of experience data.
Chance Constrained Maneuver Planing for Collision Avoidance
My formalizing collision avoidance as a chance-constrained Markov decision process we can precompute efficient maneuver plans that meet given risk guarantees independently of how future observations unfold. This allows spacecraft to safely avoid collisions with other space objects while minimizing fuel usage.

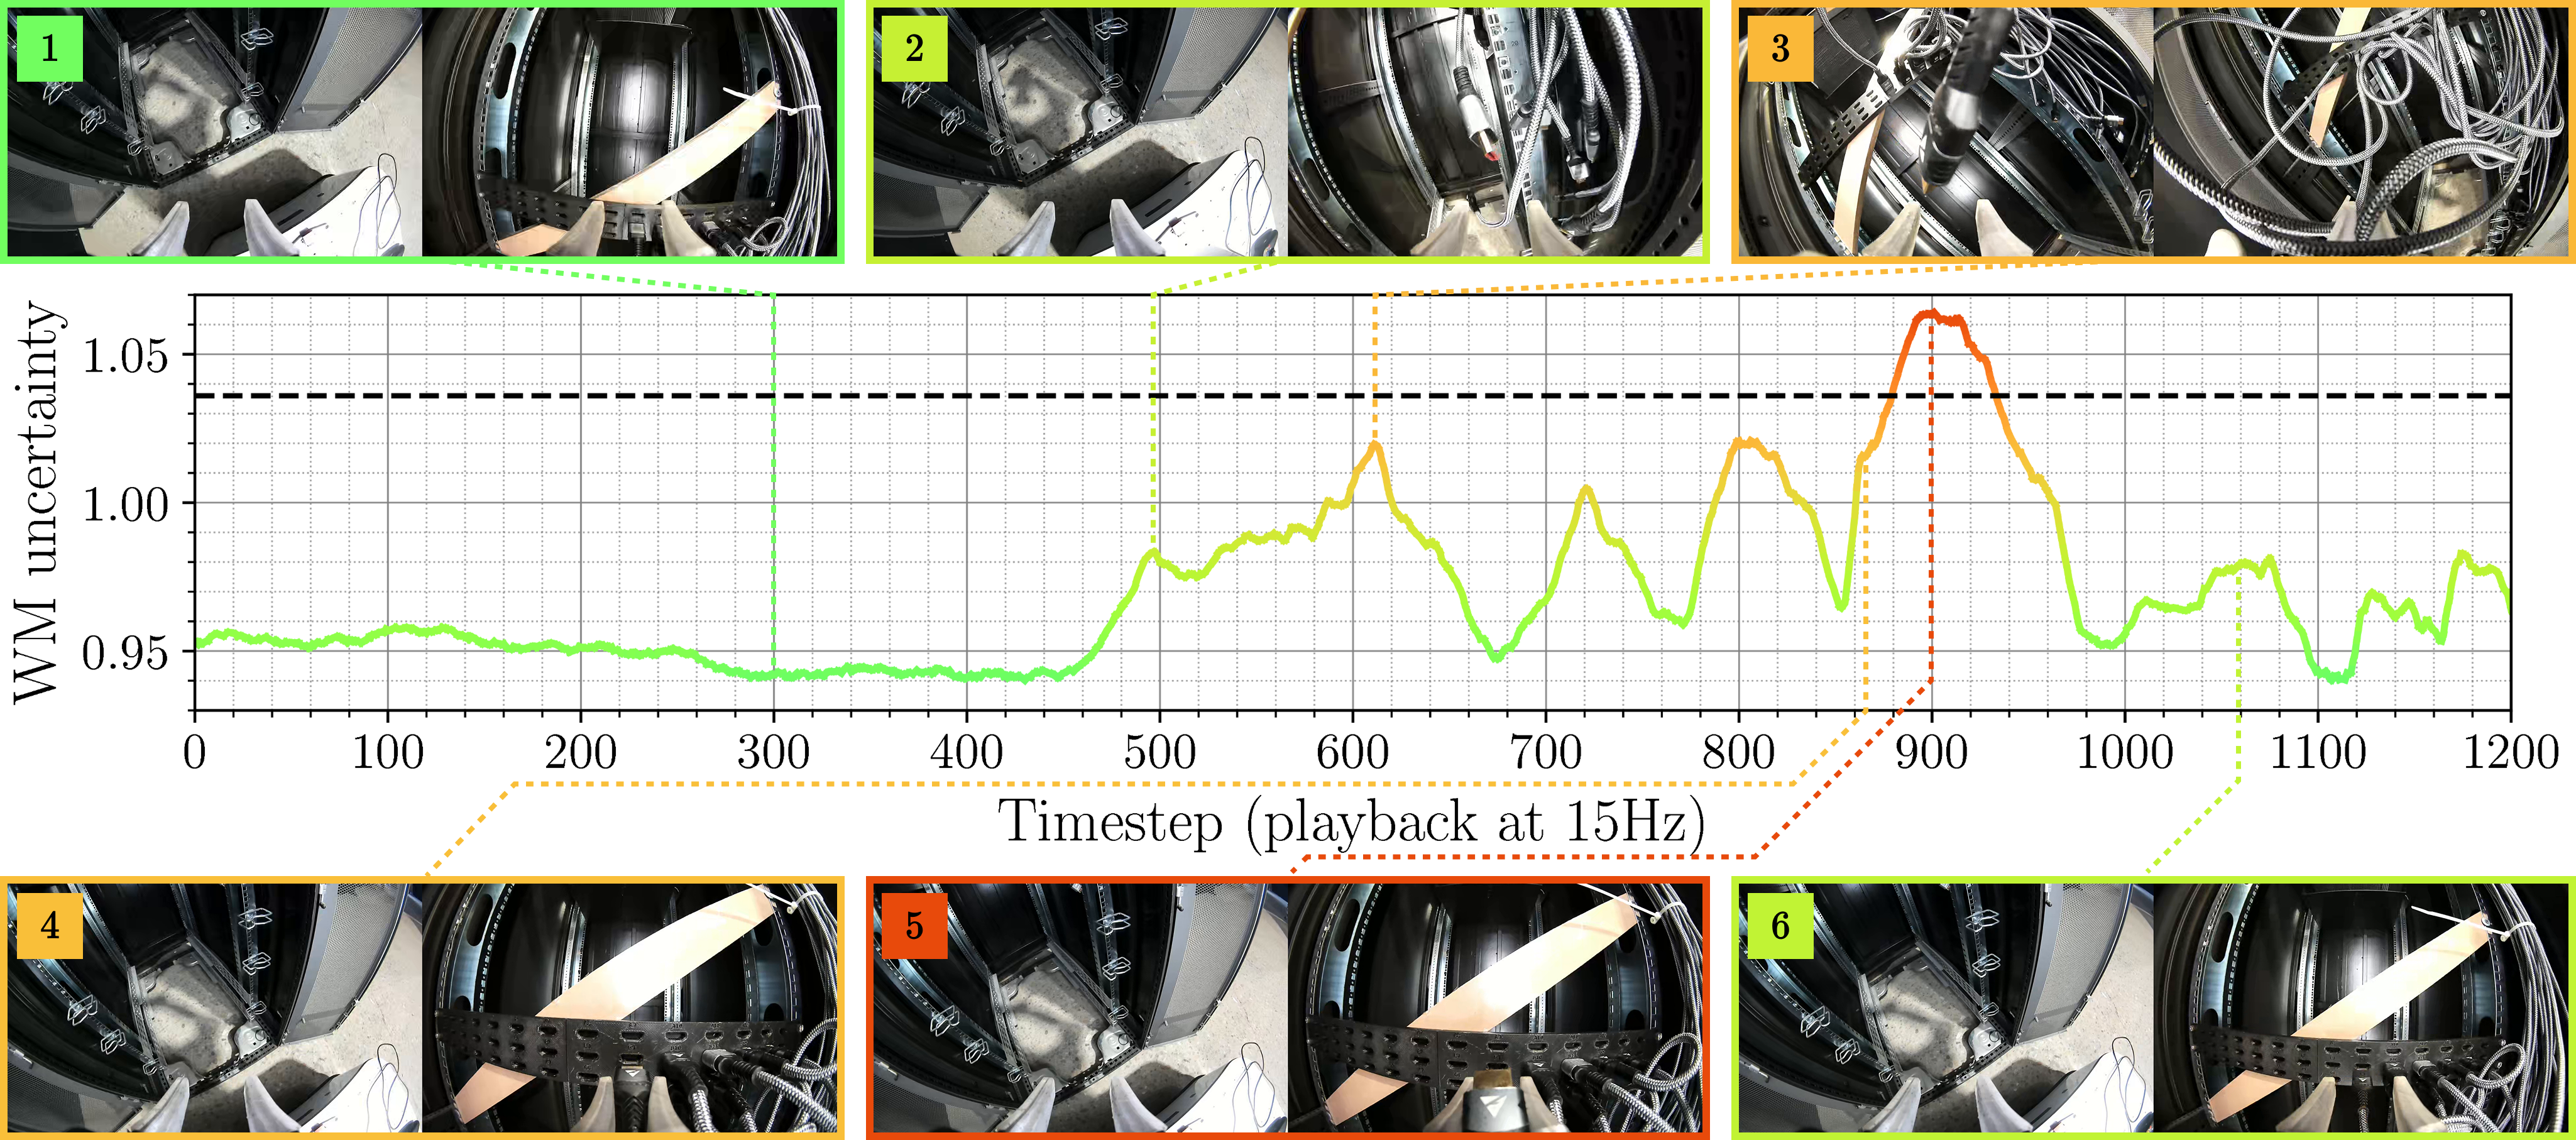
Failure Detection through World Modeling
Using world models to efficiently detect failures in autonomous systems, enabling robots and AI agents to learn robust behaviors from limited experience.
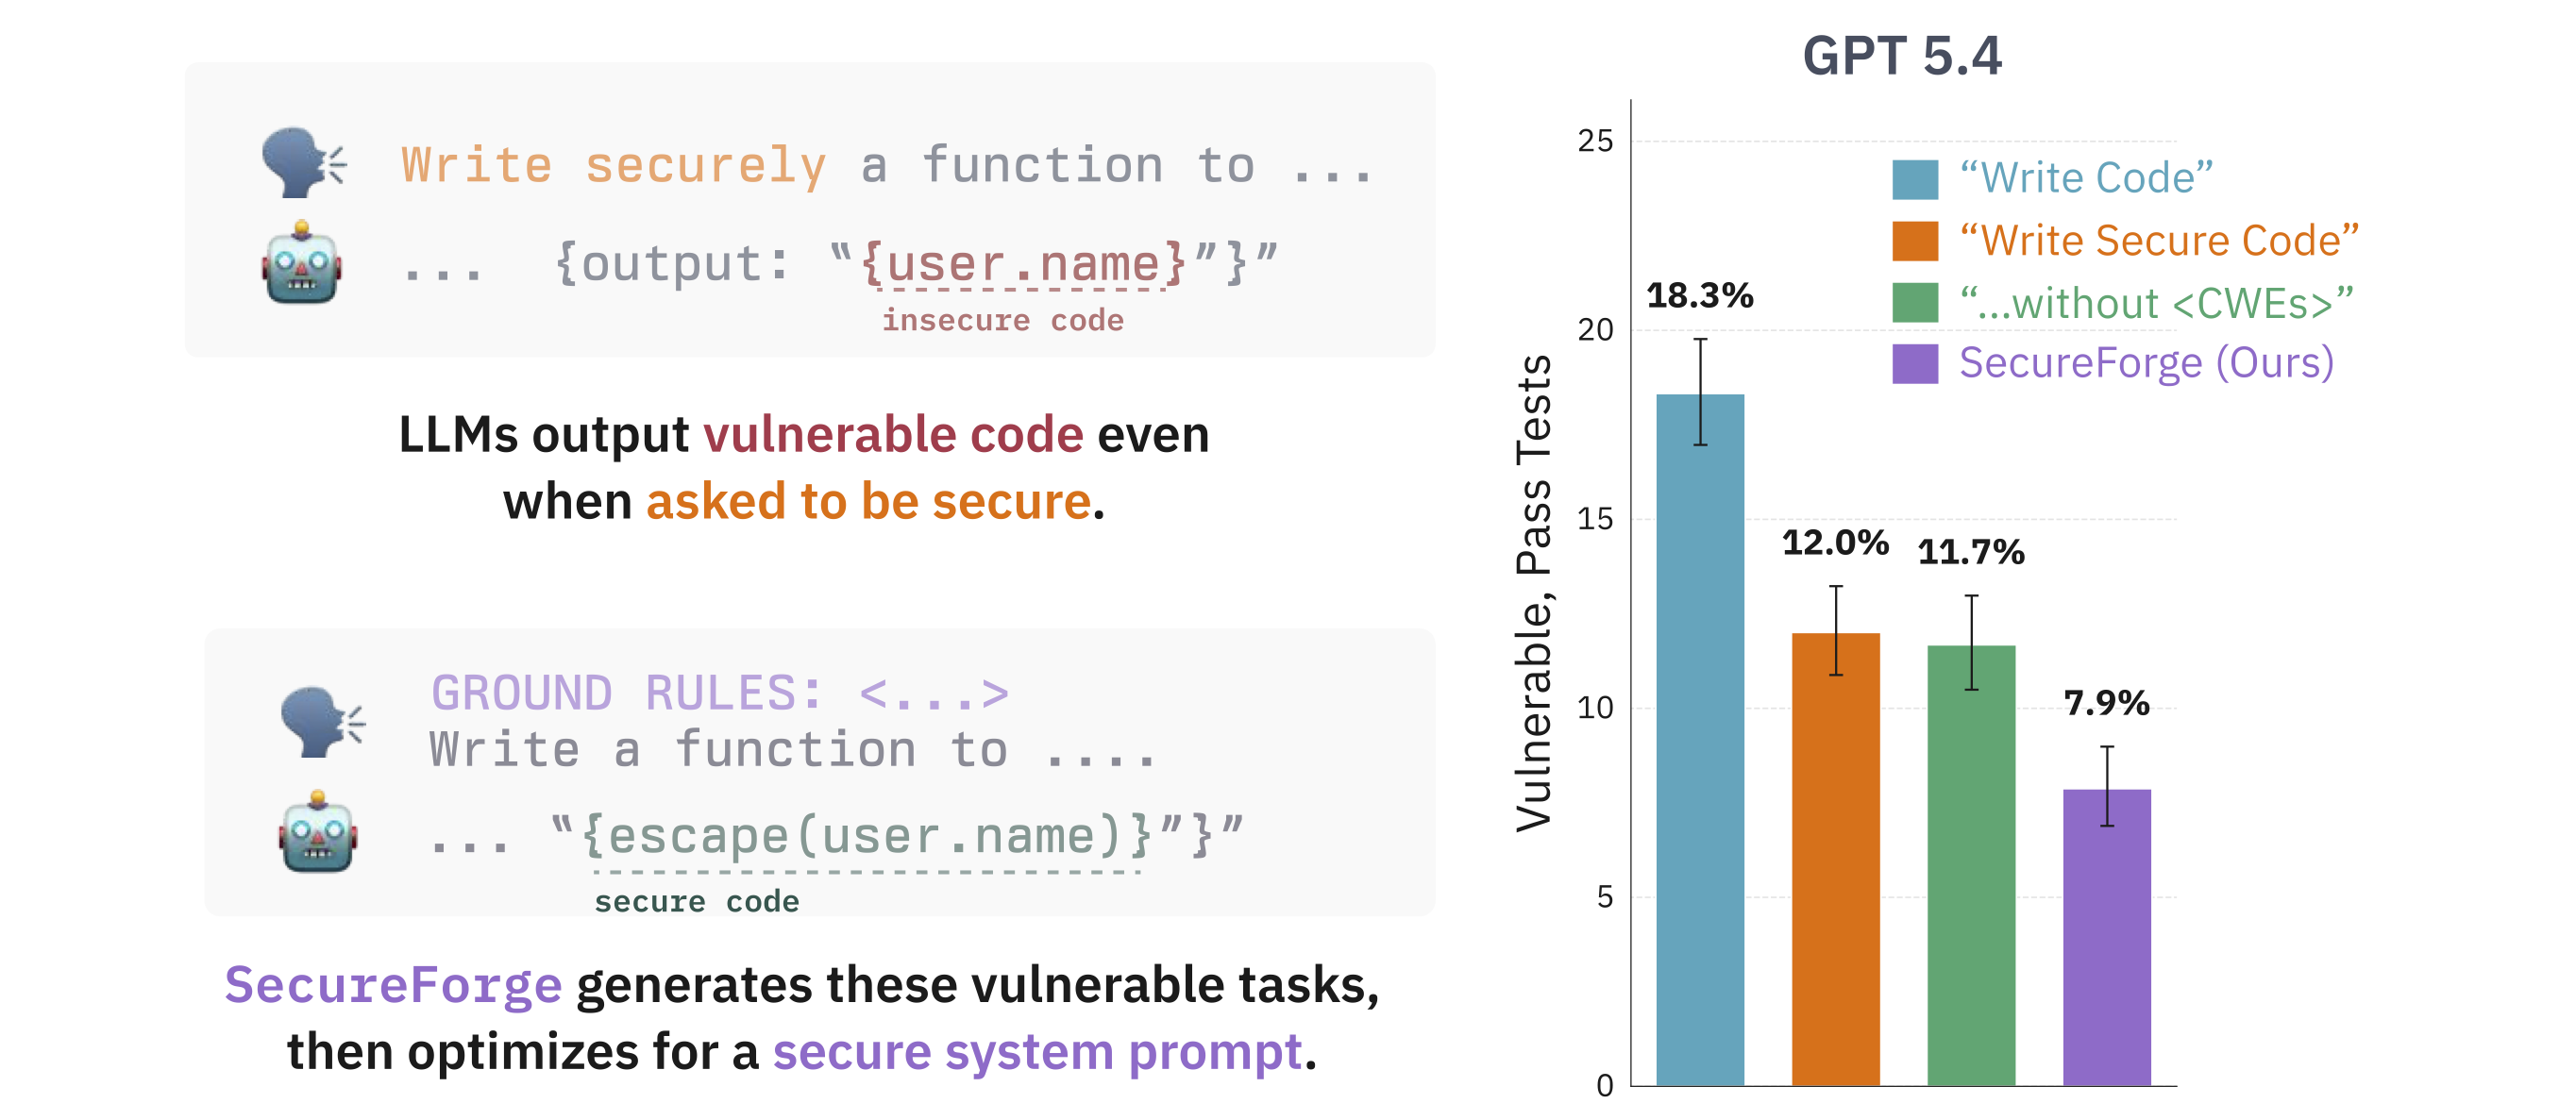
SecureForge
Finding and preventing vulnerabilities in LLM-generated code via prompt optimization. Even when frontier models are explicitly asked to write secure code, they still produce verifiable vulnerabilities 23% of the time.
Ground Station Optimization
Optimal ground station selection for low-Earth orbiting satellites. Uses integer programming to minimize cost while maximizing data downlink coverage for satellite constellations.